

EN 4709-005:2026
(Main)Aerospace series - Unmanned Aircraft Systems - Part 005: Verification method for the geocaging function
- Abstract
This document specifies requirements, test methods and pass criteria for the:
— implemented static geocage function used to prevent the UA from breaching the horizontal and vertical limits of the planned operational volume;
— information to be provided in the manufacturer’s instructions describing this function, its limits and the required size of the contingency volume after accounting the errors, reaction time and corrections.
This document does not cover the dynamic geocage function.
In addition, this document only covers the termination of the flight of the UA by the geo-caging function when breaching the OV. It does not address the compliance to the technical requirements imposed by Regulation (EU) 2019/945 on the Flight Termination System which are fully addressed by standard EN 4709-006, including the automatic triggering of the termination performed independently from the geo-caging function.
- Status
- Published
- Publication Date
- 06-Oct-2026
- Technical Committee
- CEN/TC 471 - Aviation and aeronautics
- Drafting Committee
- CEN/TC 471/WG 1 - Unmanned Aircraft Systems
- Current Stage
- 6060 - Definitive text made available (DAV) - Publishing
- Start Date
- 07-Oct-2026
- Completion Date
- 07-Oct-2026
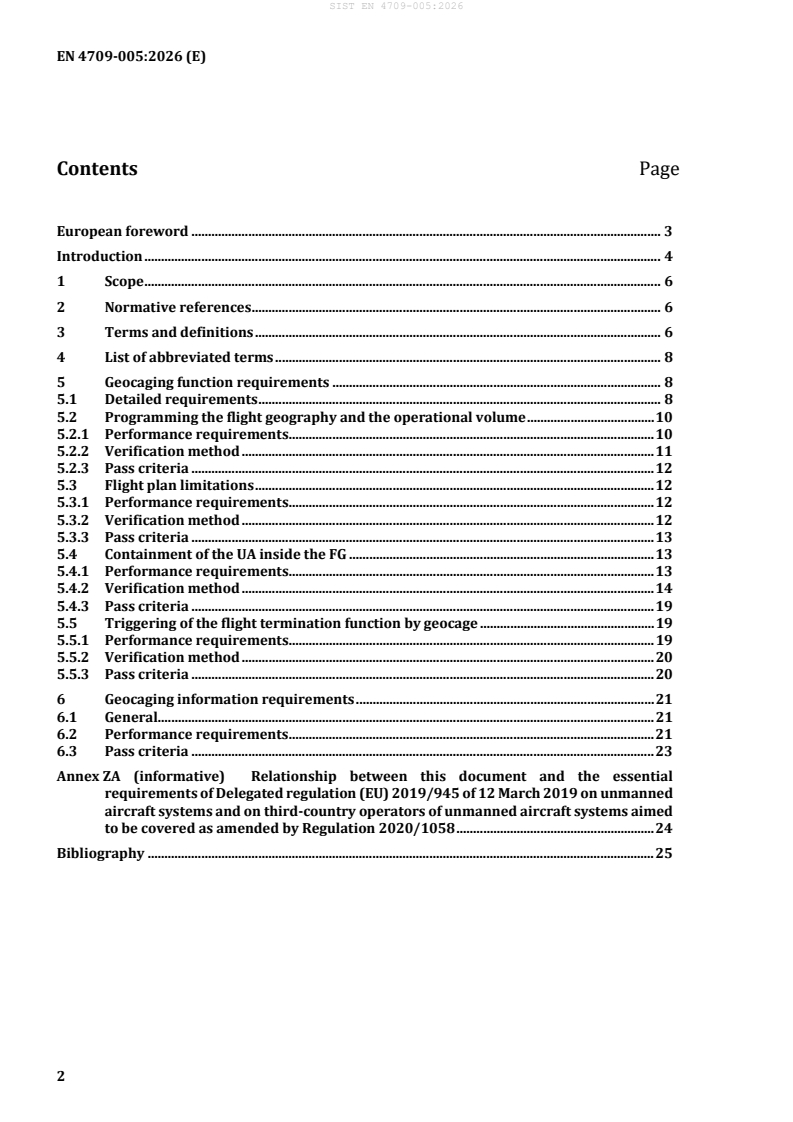
EN 4709-005:2026 is a CEN standard for aerospace unmanned aircraft systems (UAS). It specifies how to verify the geocaging function on an unmanned aircraft (UA) so the aircraft stays inside the planned flight geography and operational volume, and what the manufacturer must describe so the operator can set those limits correctly. It is written for manufacturers, operators, and conformity assessment bodies that need a common test method and pass criteria.
What does EN 4709-005:2026 specify?
EN 4709-005:2026 covers the implemented static geocage function and the related manufacturer instructions for defining the flight geography, contingency volume, and operational volume. In practice, it is about preventing a UA from leaving the planned airspace and showing, by test, that the system reacts in the right way when limits are approached or exceeded.
The scope is limited in two important ways. EN 4709-005:2026 does not cover the dynamic geocage function, and it only covers flight termination when the geo-caging function detects a breach of the operational volume. The broader technical requirements for the Flight Termination System are addressed in EN 4709-006.
The document is organized into six clauses plus one informative annex:
| Annex | What it covers |
|---|---|
| Annex ZA | Relationship between this European Standard and Regulation (EU) 2019/945, including the correspondence for the cited requirements |
What are the key requirements of EN 4709-005:2026?
EN 4709-005:2026 is mainly a verification standard. It sets out what the geocaging function must do, how it is to be tested, and what evidence is needed to show that the implementation and the manufacturer instructions are acceptable.
Programming the flight geography and operational volume
Clause 5.2 requires the remote pilot to be able to upload the operational volume limits and the contingency volume or flight geography limits before take-off. The operational volume must have at least one upper vertical limit, and the document accepts several reference types for that limit, including altitude above mean sea level (AMSL), WGS-84 based altitude, height above take-off point (ATO), height above ground level (AGL), and height as minimum Distance to Ground (DTG).
The horizontal shape must be defined either as a circle or as a polygon with controlled geometry. That matters because the system has to reject invalid inputs such as circles outside the allowed radius range, polygons with intersecting segments, or shapes with angles and segment lengths outside the manufacturer limits. If the UA is geo-aware, the instructions should also tell the operator how to check compatibility with a UAS Geographical Zone (UGZ).
Keeping the UA inside the flight geography
Clause 5.1 requires the geocaging function on the UA to do three things: keep the UA inside the flight geography in normal operation, bring it back inside the flight geography if it breaches that boundary, and trigger flight termination if it reaches the operational volume limit. The function also has to support upload of the flight geography before take-off and use the information in the manufacturer instructions when defining the contingency volume or operational volume.
Clause 5.3 adds flight plan limitations. The system must block take-off, waypoints, home positions, and landing positions outside the flight geography, and it must not allow the flight geography or operational volume to be modified in-flight. In practice, this prevents the operator from creating a plan that the geocaging system cannot safely contain.
The verification method uses bench, ground, and flight tests, and the standard requires at least three tests for each test type. The tests have to be recorded with date, time, and results, and a failure cannot be ignored or skipped over. This makes the evidence traceable for engineering review and conformity assessment.
Reaching the operational volume
Clause 5.4 requires the geocaging function to initiate an automatic contingency manoeuvre when the UA breaches the flight geography, with a caution alert to the remote pilot. The alert can be visual and may also be aural or haptic. The UA must also be able to accept manual override during the contingency manoeuvre.
The verification method is flight-based and covers different flight modes, different approach angles, and different shapes of flight geography, including concave and convex polygons and automatic return-like modes. Position checks rely on GNSS for horizontal position, in line with EN 4709-001, and on internal sensors for vertical position. This matters because the test has to show the behaviour near the actual limit, not just at a simple set point.
Clause 5.5 covers the limit of the operational volume. When the UA reaches that limit, the Flight Termination System (FTS) must be triggered automatically and the remote pilot must receive a warning alert. The tests may be destructive or non-destructive, but they have to demonstrate that the on-board FTS activation happens with the expected timing and that the warning alert is issued.
Information the manufacturer must provide
Clause 6 is about the instructions. EN 4709-005:2026 requires the manufacturer to explain the user interface, the geocaging alerts, the UA behaviour when the operational volume is breached, the automatic contingency manoeuvre, and the remote pilot override capabilities.
The instructions must also state typical and worst-case horizontal and vertical manoeuvre spans, position accuracy and standard deviation, and reaction time. These parameters are what an operator uses to size the contingency volume in a way that matches the actual aircraft behaviour and the flying conditions. Clause 6 also asks for a summary table of typical and worst-case distances, horizontally and vertically, so the operator can turn the performance data into a usable planning value.
What terms does EN 4709-005:2026 define?
- Caution alert - an alert that requires immediate awareness and a response by the remote pilot; in this document, it is tied to breach of the flight geography.
- Warning alert - an alert that requires immediate awareness and immediate response; in this document, it is tied to breach of the operational volume.
- Flight geography (FG) - the airspace volume or volumes in which the UAS operator plans to conduct the operation under normal procedures.
- Operational volume (OV) - the combined flight geography and contingency volume.
- Contingency volume - the part of the airspace outside the flight geography where contingency procedures are applied.
- Flight Termination System (FTS) - the system that is automatically triggered when the UA reaches the operational volume limit.
- Global Navigation Satellite System (GNSS) - a positioning system based on one or several satellite constellations.
- UAS Geographical Zone (UGZ) - an airspace portion established by the competent authority to facilitate, restrict, or exclude UAS operations.
Who uses EN 4709-005:2026?
EN 4709-005:2026 is aimed at economic operators such as manufacturers, importers, distributors, and their trade associations, as well as bodies involved in conformity assessment. They use it to prove compliance, define test plans, check the user interface and alerting logic, and prepare the manufacturer instructions that operators will rely on.
It is also useful to engineering, quality, and product assurance teams working on geocaging functions for UAS. In practice, those teams use it to design verification tests, document response times and limits, and decide whether the geocaging behaviour is acceptable for certification or internal release.
Which standards are used with EN 4709-005:2026?
EN 4709-005:2026 cites three normative references that contribute different parts of the overall geocaging picture:
- EN 4709-001 - provides product requirements and verification, and is also the basis for the GNSS guidance used in position measurement.
- EN 4709-006 - provides the requirements and verification for means to terminate flight, including the Flight Termination System referenced when the operational volume is breached.
- EN 4709-007 - provides general product requirements for UAS classes C5 and C6, and is referenced for how the operational volume limits, including flight geography and contingency information, are displayed.
What does the EN 4709-005:2026 document contain?
EN 4709-005:2026 contains detailed performance requirements, verification methods, and pass criteria for geocaging behaviour. Clause 5 includes test setups for programming limits, rejecting invalid flight plans, keeping the UA inside the flight geography, and triggering the FTS when the operational volume is reached.
The document also includes several illustrated test cases. Figures 1 to 14 show the SORA semantic model and the flight-test geometries for horizontal limits, vertical limits, sharp angles, and automatic return-like behaviour. Those figures are there to help the reader understand how the tests are performed, not to repeat the rules in prose.
Clause 6 contains the manufacturer information checklist used for operator planning, including manoeuvre span, accuracy, reaction time, and summary distance data. Annex ZA provides the regulatory correspondence table linking the standard to Regulation (EU) 2019/945.
Relations
- Effective Date
- 21-Oct-2026
- Effective Date
- 21-Oct-2026
- Effective Date
- 21-Oct-2026
Get Certified
Connect with accredited certification bodies for this standard

BSI Group
BSI (British Standards Institution) is the business standards company that helps organizations make excellence a habit.

Bureau Veritas
Bureau Veritas is a world leader in laboratory testing, inspection and certification services.
DNV
DNV is an independent assurance and risk management provider.
Sponsored listings
Frequently Asked Questions
EN 4709-005:2026 is a standard published by the European Committee for Standardization (CEN). Its full title is "Aerospace series - Unmanned Aircraft Systems - Part 005: Verification method for the geocaging function". This standard covers: This document specifies requirements, test methods and pass criteria for the: — implemented static geocage function used to prevent the UA from breaching the horizontal and vertical limits of the planned operational volume; — information to be provided in the manufacturer’s instructions describing this function, its limits and the required size of the contingency volume after accounting the errors, reaction time and corrections. This document does not cover the dynamic geocage function. In addition, this document only covers the termination of the flight of the UA by the geo-caging function when breaching the OV. It does not address the compliance to the technical requirements imposed by Regulation (EU) 2019/945 on the Flight Termination System which are fully addressed by standard EN 4709-006, including the automatic triggering of the termination performed independently from the geo-caging function.
This document specifies requirements, test methods and pass criteria for the: — implemented static geocage function used to prevent the UA from breaching the horizontal and vertical limits of the planned operational volume; — information to be provided in the manufacturer’s instructions describing this function, its limits and the required size of the contingency volume after accounting the errors, reaction time and corrections. This document does not cover the dynamic geocage function. In addition, this document only covers the termination of the flight of the UA by the geo-caging function when breaching the OV. It does not address the compliance to the technical requirements imposed by Regulation (EU) 2019/945 on the Flight Termination System which are fully addressed by standard EN 4709-006, including the automatic triggering of the termination performed independently from the geo-caging function.
EN 4709-005:2026 is classified under the following ICS (International Classification for Standards) categories: 03.220.50 - Air transport; 49.020 - Aircraft and space vehicles in general. The ICS classification helps identify the subject area and facilitates finding related standards.
EN 4709-005:2026 has the following relationships with other standards: It is inter standard links to EN 4709-001:2026, EN 4709-007:2026, EN 4709-006:2026. Understanding these relationships helps ensure you are using the most current and applicable version of the standard.
EN 4709-005:2026 is associated with the following European legislation: EU Directives/Regulations: 2019/945; Standardization Mandates: M/567. When a standard is cited in the Official Journal of the European Union, products manufactured in conformity with it benefit from a presumption of conformity with the essential requirements of the corresponding EU directive or regulation.
EN 4709-005:2026 is available in PDF format for immediate download after purchase. The document can be added to your cart and obtained through the secure checkout process. Digital delivery ensures instant access to the complete standard document.
Standards Content (Sample)
SLOVENSKI STANDARD
01-december-2026
Aeronavtika - Letalski sistemi brez posadke - 005. del: Metoda preverjanja funkcije
Geocaging
Aerospace series - Unmanned Aircraft Systems - Part 005: Verification method for the
Geocaging function
Luft- und Raumfahrt - Unbemannte Luftfahrzeugsysteme - Teil 005:
Überprüfungsmethode für die Geocaging-Funktion
Série aérospatiale - Aéronefs télépilotés - Partie 005: Méthode de vérification de la
fonction géeocaging
Ta slovenski standard je istoveten z: EN 4709-005:2026
ICS:
03.220.50 Zračni transport Air transport
49.020 Letala in vesoljska vozila na Aircraft and space vehicles in
splošno general
2003-01.Slovenski inštitut za standardizacijo. Razmnoževanje celote ali delov tega standarda ni dovoljeno.
EN 4709-005
EUROPEAN STANDARD
NORME EUROPÉENNE
October 2026
EUROPÄISCHE NORM
ICS 03.220.50; 49.020
English Version
Aerospace series - Unmanned Aircraft Systems - Part 005:
Verification method for the geocaging function
Série aérospatiale - Aéronefs télépilotés - Partie 005 : Luft- und Raumfahrt - Unbemannte
Méthode de vérification de la fonction de géocage Luftfahrzeugsysteme - Teil 005: Überprüfungsmethode
für die Geocaging-Funktion
This European Standard was approved by CEN on 21 April 2025.
CEN members are bound to comply with the CEN/CENELEC Internal Regulations which stipulate the conditions for giving this
European Standard the status of a national standard without any alteration. Up-to-date lists and bibliographical references
concerning such national standards may be obtained on application to the CEN-CENELEC Management Centre or to any CEN
member.
This European Standard exists in three official versions (English, French, German). A version in any other language made by
translation under the responsibility of a CEN member into its own language and notified to the CEN-CENELEC Management
Centre has the same status as the official versions.
CEN members are the national standards bodies of Austria, Belgium, Bulgaria, Croatia, Cyprus, Czech Republic, Denmark, Estonia,
Finland, France, Germany, Greece, Hungary, Iceland, Ireland, Italy, Latvia, Lithuania, Luxembourg, Malta, Netherlands, Norway,
Poland, Portugal, Republic of North Macedonia, Romania, Serbia, Slovakia, Slovenia, Spain, Sweden, Switzerland, Türkiye and
United Kingdom.
EUROPEAN COMMITTEE FOR STANDARDIZATION
COMITÉ EUROPÉEN DE NORMALISATION
EUROPÄISCHES KOMITEE FÜR NORMUNG
CEN-CENELEC Management Centre: Rue de la Science 23, B-1040 Brussels
© 2026 CEN All rights of exploitation in any form and by any means reserved Ref. No. EN 4709-005:2026 E
worldwide for CEN national Members.
Contents Page
European foreword . 3
Introduction . 4
1 Scope . 6
2 Normative references . 6
3 Terms and definitions . 6
4 List of abbreviated terms . 8
5 Geocaging function requirements . 8
5.1 Detailed requirements . 8
5.2 Programming the flight geography and the operational volume . 10
5.2.1 Performance requirements . 10
5.2.2 Verification method . 11
5.2.3 Pass criteria . 12
5.3 Flight plan limitations . 12
5.3.1 Performance requirements . 12
5.3.2 Verification method . 12
5.3.3 Pass criteria . 13
5.4 Containment of the UA inside the FG . 13
5.4.1 Performance requirements . 13
5.4.2 Verification method . 14
5.4.3 Pass criteria . 19
5.5 Triggering of the flight termination function by geocage . 19
5.5.1 Performance requirements . 19
5.5.2 Verification method . 20
5.5.3 Pass criteria . 20
6 Geocaging information requirements . 21
6.1 General. 21
6.2 Performance requirements . 21
6.3 Pass criteria . 23
Annex ZA (informative) Relationship between this document and the essential
requirements of Delegated regulation (EU) 2019/945 of 12 March 2019 on unmanned
aircraft systems and on third-country operators of unmanned aircraft systems aimed
to be covered as amended by Regulation 2020/1058 . 24
Bibliography . 25
European foreword
This document (EN 4709-005:2026) has been prepared by Technical Committee CEN/TC 471
“Unmanned Aircraft Systems”, the secretariat of which is held by BNAE.
This European Standard shall be given the status of a national standard, either by publication of an
identical text or by endorsement, at the latest by April 2027, and conflicting national standards shall be
withdrawn at the latest by April 2027.
Attention is drawn to the possibility that some of the elements of this document may be the subject of
patent rights. CEN shall not be held responsible for identifying any or all such patent rights.
This document has been prepared under a Standardization Request given to CEN by the European
Commission and the European Free Trade Association and supports essential requirements of
EU Directive(s)/Regulation(s).
For relationship with EU Directive(s)/Regulation(s), see informative Annex ZA, which is an integral part
of this document.
Any feedback and questions on this document should be directed to the users’ national standards body.
A complete listing of these bodies can be found on the CEN website.
According to the CEN-CENELEC Internal Regulations, the national standards organisations of the
following countries are bound to implement this European Standard: Austria, Belgium, Bulgaria, Croatia,
Cyprus, Czech Republic, Denmark, Estonia, Finland, France, Germany, Greece, Hungary, Iceland, Ireland,
Italy, Latvia, Lithuania, Luxembourg, Malta, Netherlands, Norway, Poland, Portugal, Republic of North
Macedonia, Romania, Serbia, Slovakia, Slovenia, Spain, Sweden, Switzerland, Türkiye and the United
Kingdom.
Introduction
This document gives all economic operators (such as manufacturers, importers and distributors and their
trade associations as well as bodies involved in the conformity assessment procedures) a viable way to
prove compliance with the requirements of the C6 class marked UAS linked to geocaging function and to
find commonality in compliance methods.
The end user of this document assumes all responsibility for the safe application of the test methods.
All relevant safety/quality procedures should be considered. Special consideration should be given to the
operation of the UAS for evaluations. All local, state, federal, and national laws should be considered when
operating any UAS.
Operational volume and contingency volume are defined in SORA semantic model. Figure 1 provides a
consistent use of the terms. Figure 2 provides a graphical representation of the model.
Figure 1 — SORA semantic model [Source: Easy Access Rules for Unmanned Aircraft Systems,
September 2022]
Figure 2 — Graphical representation of the SORA semantic model [Source: Easy Access Rules for
Unmanned Aircraft Systems, September 2022]
NOTE 1 SORA Step #9 – Adjacent area/airspace considerations and PDRA-G01, G02 and G03.
This document provides a contribution to SORA Step #9 compliance, requirement (b), also known as
Standard containment. Nonetheless, this document cannot be used as a complete means of compliance to
SORA Step #9, as it does not include design requirements.
NOTE 2 PDRA-G01, G02 and G03 also include this requirement in section Technical provisions, Containment.
1 Scope
This document specifies requirements, test methods and pass criteria for the:
— implemented static geocage function used to prevent the UA from breaching the horizontal and
vertical limits of the planned operational volume;
— information to be provided in the manufacturer’s instructions describing this function, its limits and
the required size of the contingency volume after accounting the errors, reaction time and
corrections.
This document does not cover the dynamic geocage function.
In addition, this document only covers the termination of the flight of the UA by the geo-caging function
when breaching the OV. It does not address the compliance to the technical requirements imposed by
Regulation (EU) 2019/945 on the Flight Termination System which are fully addressed by standard EN
4709-006, including the automatic triggering of the termination performed independently from the geo-
caging function.
2 Normative references
The following documents are referred to in the text in such a way that some or all of their content
constitutes requirements of this document. For dated references, only the edition cited applies. For
undated references, the latest edition of the referenced document (including any amendments) applies.
EN 4709-001:2026, Aerospace series — Unmanned Aircraft Systems — Part 001: Product requirements
and verification
EN 4709-006:2026, Aerospace series — Unmanned Aircraft Systems — Part 006: Means to terminate flight,
requirements, and verification
EN 4709-007:2026, Aerospace series — Unmanned Aircraft Systems — Part 007: General product
requirements for UAS classes C5 and C6
3 Terms and definitions
For the purposes of this document, the terms and definitions given in EN 4709-001:2026 and the
following apply.
ISO and IEC maintain terminology databases for use in standardization at the following addresses:
— ISO Online browsing platform: available at https://www.iso.org/obp/
— IEC Electropedia: available at https://www.electropedia.org/
3.1
caution alert
alert for conditions that require immediate awareness and subsequent response by the UAS remote pilot
Note 1 to entry: In this document, the caution alert condition is related to the breach of the flight geography volume.
3.2
command unit
equipment or system of equipment to control unmanned aircraft remotely as defined in point 32 of
Article 3 of Regulation (EU) 2018/1139 which supports the control or the monitoring of the unmanned
aircraft during any phase of flight, with the exception of any infrastructure supporting the command and
control (C2) link service
[SOURCE: Easy Access Rules for Unmanned Aircraft Systems, September 2022]
3.3
contingency procedure
preventive or corrective action to be taken in response to an event and a need to depart from the agreed
plan of action
3.4
contingency volume
volume of airspace outside the flight geography where contingency procedures are applied
[SOURCE: Easy Access Rules for Unmanned Aircraft Systems, September 2022]
3.5
flight geography
volume(s) of airspace defined spatially and temporally in which the UAS operator plans to conduct the
operation under normal procedures
[SOURCE: Easy Access Rules for Unmanned Aircraft Systems, September 2022]
3.6
global navigation satellite system
GNSS
positioning system based on one or several satellite constellations
3.7
haptic signal
type of signal that is transferred to the hand of the user through the handheld controller in the form of
vibrations
3.8
operational volume
combination of the flight geography and the contingency volume
[SOURCE: Easy Access Rules for Unmanned Aircraft Systems, September 2022]
3.9
UAS geographical zone
UGZ
portion of airspace established by the competent authority that facilitates, restricts, or excludes UAS
operations in order to address risks pertaining to safety, privacy, protection of personal data, security, or
the environment, arising from UAS operations
[SOURCE: Easy Access Rules for Unmanned Aircraft Systems, September 2022]
3.10
warning alert
alert for conditions that require immediate awareness and immediate response by the UAS remote pilot
Note 1 to entry: in this document, the warning alert condition is related to the breach of the operational volume.
4 List of abbreviated terms
AGL Above Ground Level
AMSL Above Mean Sea Level
ATO Above Take-Off Point
DTG Distance to Ground
FG Flight Geography
FTS Flight Termination system
GNSS Global Navigation Satellite System
OV Operational Volume
PDRA Pre-Defined Risk Assessment
RP Remote Pilot
RPS Remote Pilot Station
RTH Return To Home
SORA Specific Operations Risk Assessment
UA Unmanned Aircraft
UAS Unmanned Aircraft System
UGZ UAS Geographical Zone
VLOS Visual Line of Sight
5 Geocaging function requirements
5.1 Detailed requirements
The geocaging function shall provide a way to program the flight geography and the operational volume.
The geocaging function shall be implemented on the UA and achieve the following objectives:
(1) ensure that, in normal operation, the UA is maintained inside the flight geography;
(2) once breaching the FG, the geocage function shall trigger automatic contingency procedure;
(3) once breaching the operational volume, the geocage function shall automatically end the flight.
Those objectives require:
a) the upload before take-off of the flight geography; and
b) the upload before take-off of the contingency volume or the operational volume, taking into account
the information provided in the manufacturer instructions.
Achieving the first objective (1) requires:
c) the flight plan limitation (prohibition of take-off, landing, waypoints, trajectory, home points or any
automatic command outside the FG).
Achieving the second objective (2) requires:
d) triggering of a caution alert when the UA breaches the limits of the FG. The caution alert could be
visual with one or more of the following: aural (sound) and/or haptic;
e) an automatic contingency manoeuvre aimed to bring back the UA inside the Flight Geography (FG).
It shall be triggered when the UA breaches the flight geography limits taking into account
positioning/accuracy errors.
Achieving the third objective (3) requires:
f) triggering of a warning alert when the UA breaches the limits of the operational volume;
g) the automatic triggering of the Flight Termination System (FTS) when the UA breaches the limits of
the operational volume.
NOTE The validation of manufacturer instructions to define the ground risk buffer is considered out of the scope
of this document and is treated in EN 4709-006:2026 FTS document.
The compliance of the geocaging function towards these requirements is described in 5.2 to 5.6 included.
Figure 3 illustrates the geocage function outputs.
Figure 3 — Graphical representation of SORA semantic model and the geocaging function
[Source: Easy Access Rules for Unmanned Aircraft Systems, September 2022, with modifications]
5.2 Programming the flight geography and the operational volume
5.2.1 Performance requirements
(1) The remote pilot shall be able to upload the limits of the operational volume.
(2) The remote pilot shall be able to upload the size of the contingency volume or the limits of the FG of
the intended operation. The manufacturer may choose to set a minimum and maximum size for the
contingency zone.
(3) The operational volume limits shall be defined with a minimum of a single upper altitude/height
vertical limit. The vertical limit reference shall be up to the manufacturer and defined in the
manufacturer instructions, and include at least one of the following:
— altitude above mean sea level (AMSL);
— altitude defined by WGS-84 system;
— height above take-off point (ATO);
— height above ground level (AGL);
— height as the minimum Distance to Ground (DTG ).
Figure 4 — Maximum height illustration [Source: reprinted from Easy Access Rules for Unmanned
Aircraft Systems, September 2022]
(4) The horizontal shape of the operational volume limits shall be specified in the manufacturer's
instruction:
a) as a circle with a minimum and maximum radius; or
b) as a polygon with:
i. concave angles and convex angles not sharper than a value specified by the manufacturer;
ii. segments longer than the minimum specified by the manufacturer;
Perpendicular distance from the UA to the ground. It differs from the height above ground level only when steep
terrains are considered as illustrated in Figure 4 between the red and white arrows.
iii. no intersecting segments.
(5) The geocage loading system shall ensure the data loaded in the UA correspond to the limits of the FG
and OV displayed on the user interface:
a) the display of the FG and contingency volume shall be available during the whole flight;
b) user interface shall show if the limits are correctly loaded into the UA;
c) user interface shall show when the system is not able to upload the FG and OV limits;
d) user interface shall show when no limits are loaded into the UA.
5.2.2 Verification method
(1) Verify that the UAS provides an interface to set and modify the operational volume limits and the
contingency volume.
(2) Verify that the manufacturer’s instructions include the following information:
a) maximum number of vertical limits accepted;
b) vertical limit references accepted (AMSL, WGS84, ATO, AGL, DTG);
c) horizontal shape accepted (circle, polygon):
i. where circles are an acceptable horizontal shape, then verify that the minimum and
maximum radius are provided;
ii. if polygons are an acceptable horizontal shape, then verify that the sharpest angle and
maximum number of corners are provided.
(3) Verify that the geocaging system does not accept operational volume limits and shapes beyond the
ones defined in the manufacturer instructions and identified in 5.2.1 (4).
(4) Verify the geocage loading system and display:
a) turn on the UA and the geocaging user interface:
i. set up a simple geocage (circle or polygon);
ii. send the geocage to the UA;
b) turn off the UA while keeping the user interface on:
i. send a geocage while UA is off, and check that the limits were not loaded;
c) turn on the UA:
i. check if the limits sent through step (2)a) were loaded;
ii. send the geocage to the UA, and re-check;
d) modify the geocage on the user interface, then send it to the UA;
e) verify that the limits of the OV (including the FG and contingency) are displayed as per
EN 4709-007:2026;
f) try starting a flight without loading a geocage function and check if an alert is triggered.
...